

Contact
About Us
Applications
Welding Positioners
Industrial Robots
Home


Loading product...

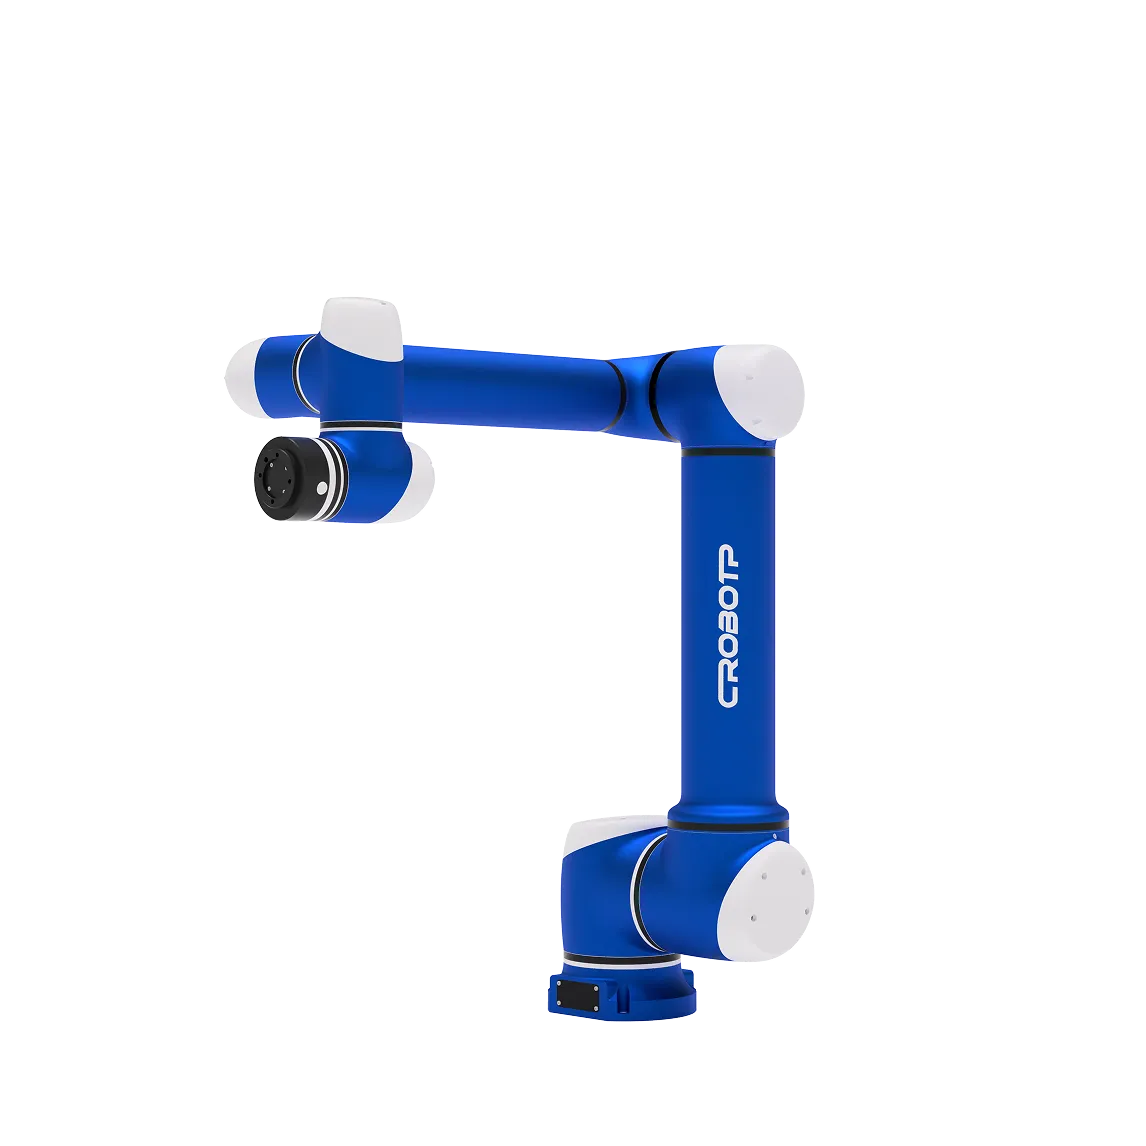


Collaborative robot RC13-10 is an industrial collaborative robot: 6 axes, 10 kg payload, 1320 mm reach, ±0.03 mm repeatability. It is built for handling and other repetitive work where cycle time and consistency decide the cost per part.
Size it by the two constraints that cannot be worked around: the mass at the wrist — part, gripper, cabling and any sensor together — and the furthest point the tool must reach at full extension. Everything else follows from those.
Designed to work alongside people without fencing, subject to a risk assessment of the complete cell — the robot being collaborative is not by itself sufficient. Suits short runs and frequent changeovers; for continuous production of one part all shift, compare against a fenced industrial arm.