

Contact
About Us
Applications
Welding Positioners
Industrial Robots
Home


Loading product...

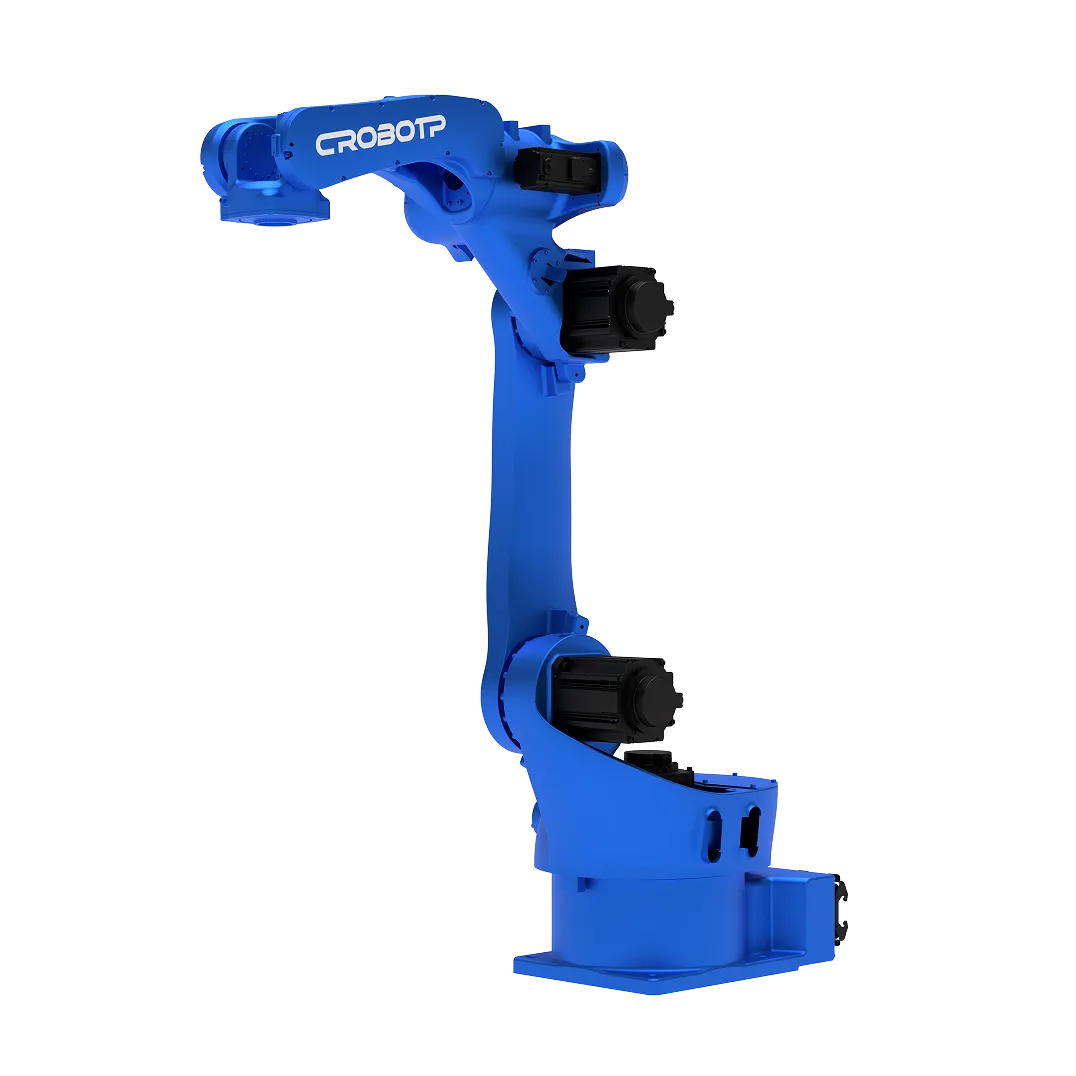
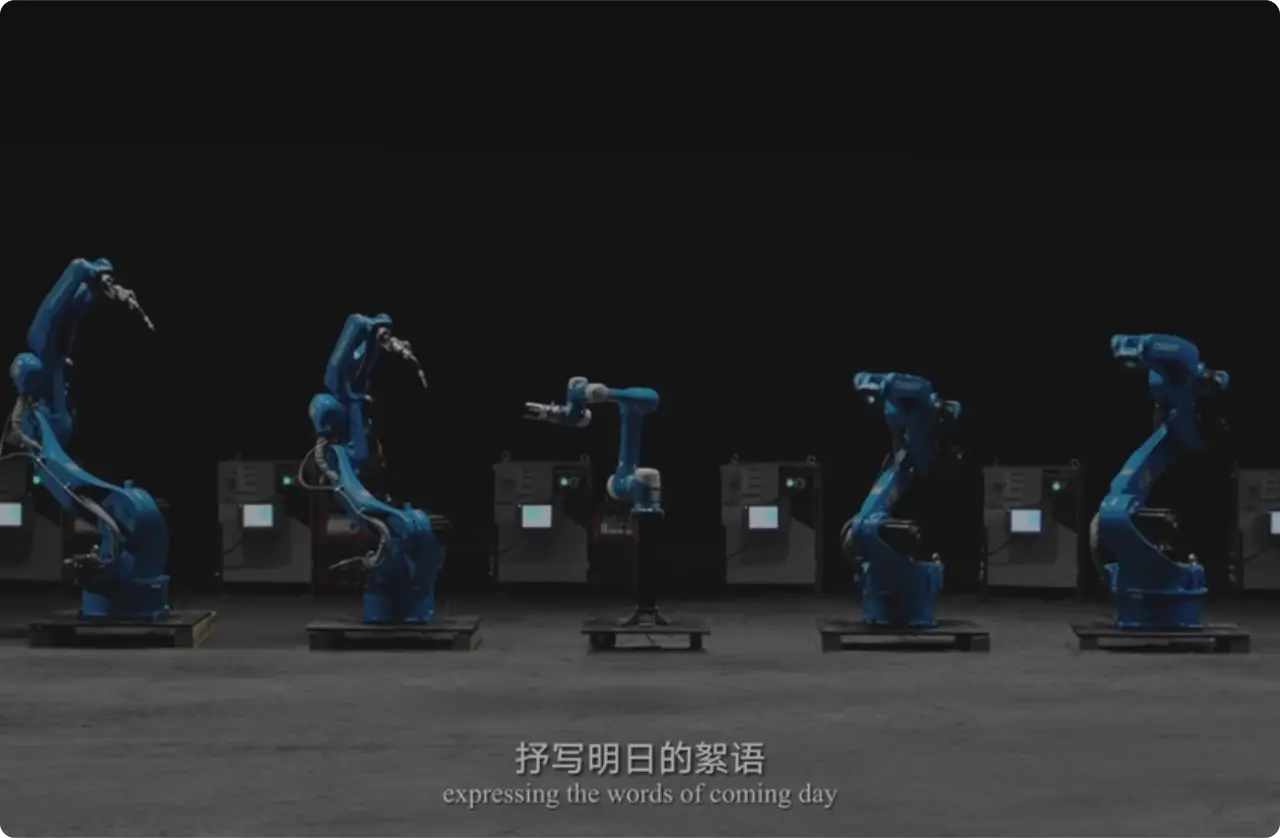


Industrial robot arm RH14-10 is an industrial six-axis handling robot: 6 axes, 10 kg payload, 1454 mm reach, ±0.08 mm repeatability. It is built for palletizing, handling, assembly, marking and loading/unloading parts and other repetitive work where cycle time and consistency decide the cost per part.
Size it by the two constraints that cannot be worked around: the mass at the wrist — part, gripper, cabling and any sensor together — and the furthest point the tool must reach at full extension. Everything else follows from those.
Six axes let the tool approach from any angle — reaching into a machine, tilting a part to clear a fixture, placing at an angle. Where the approach is always vertical and the part flat, a SCARA or a four-axis palletizer does the job; for stacking, a four-axis palletizing robot is faster.